Terradynamics Lab
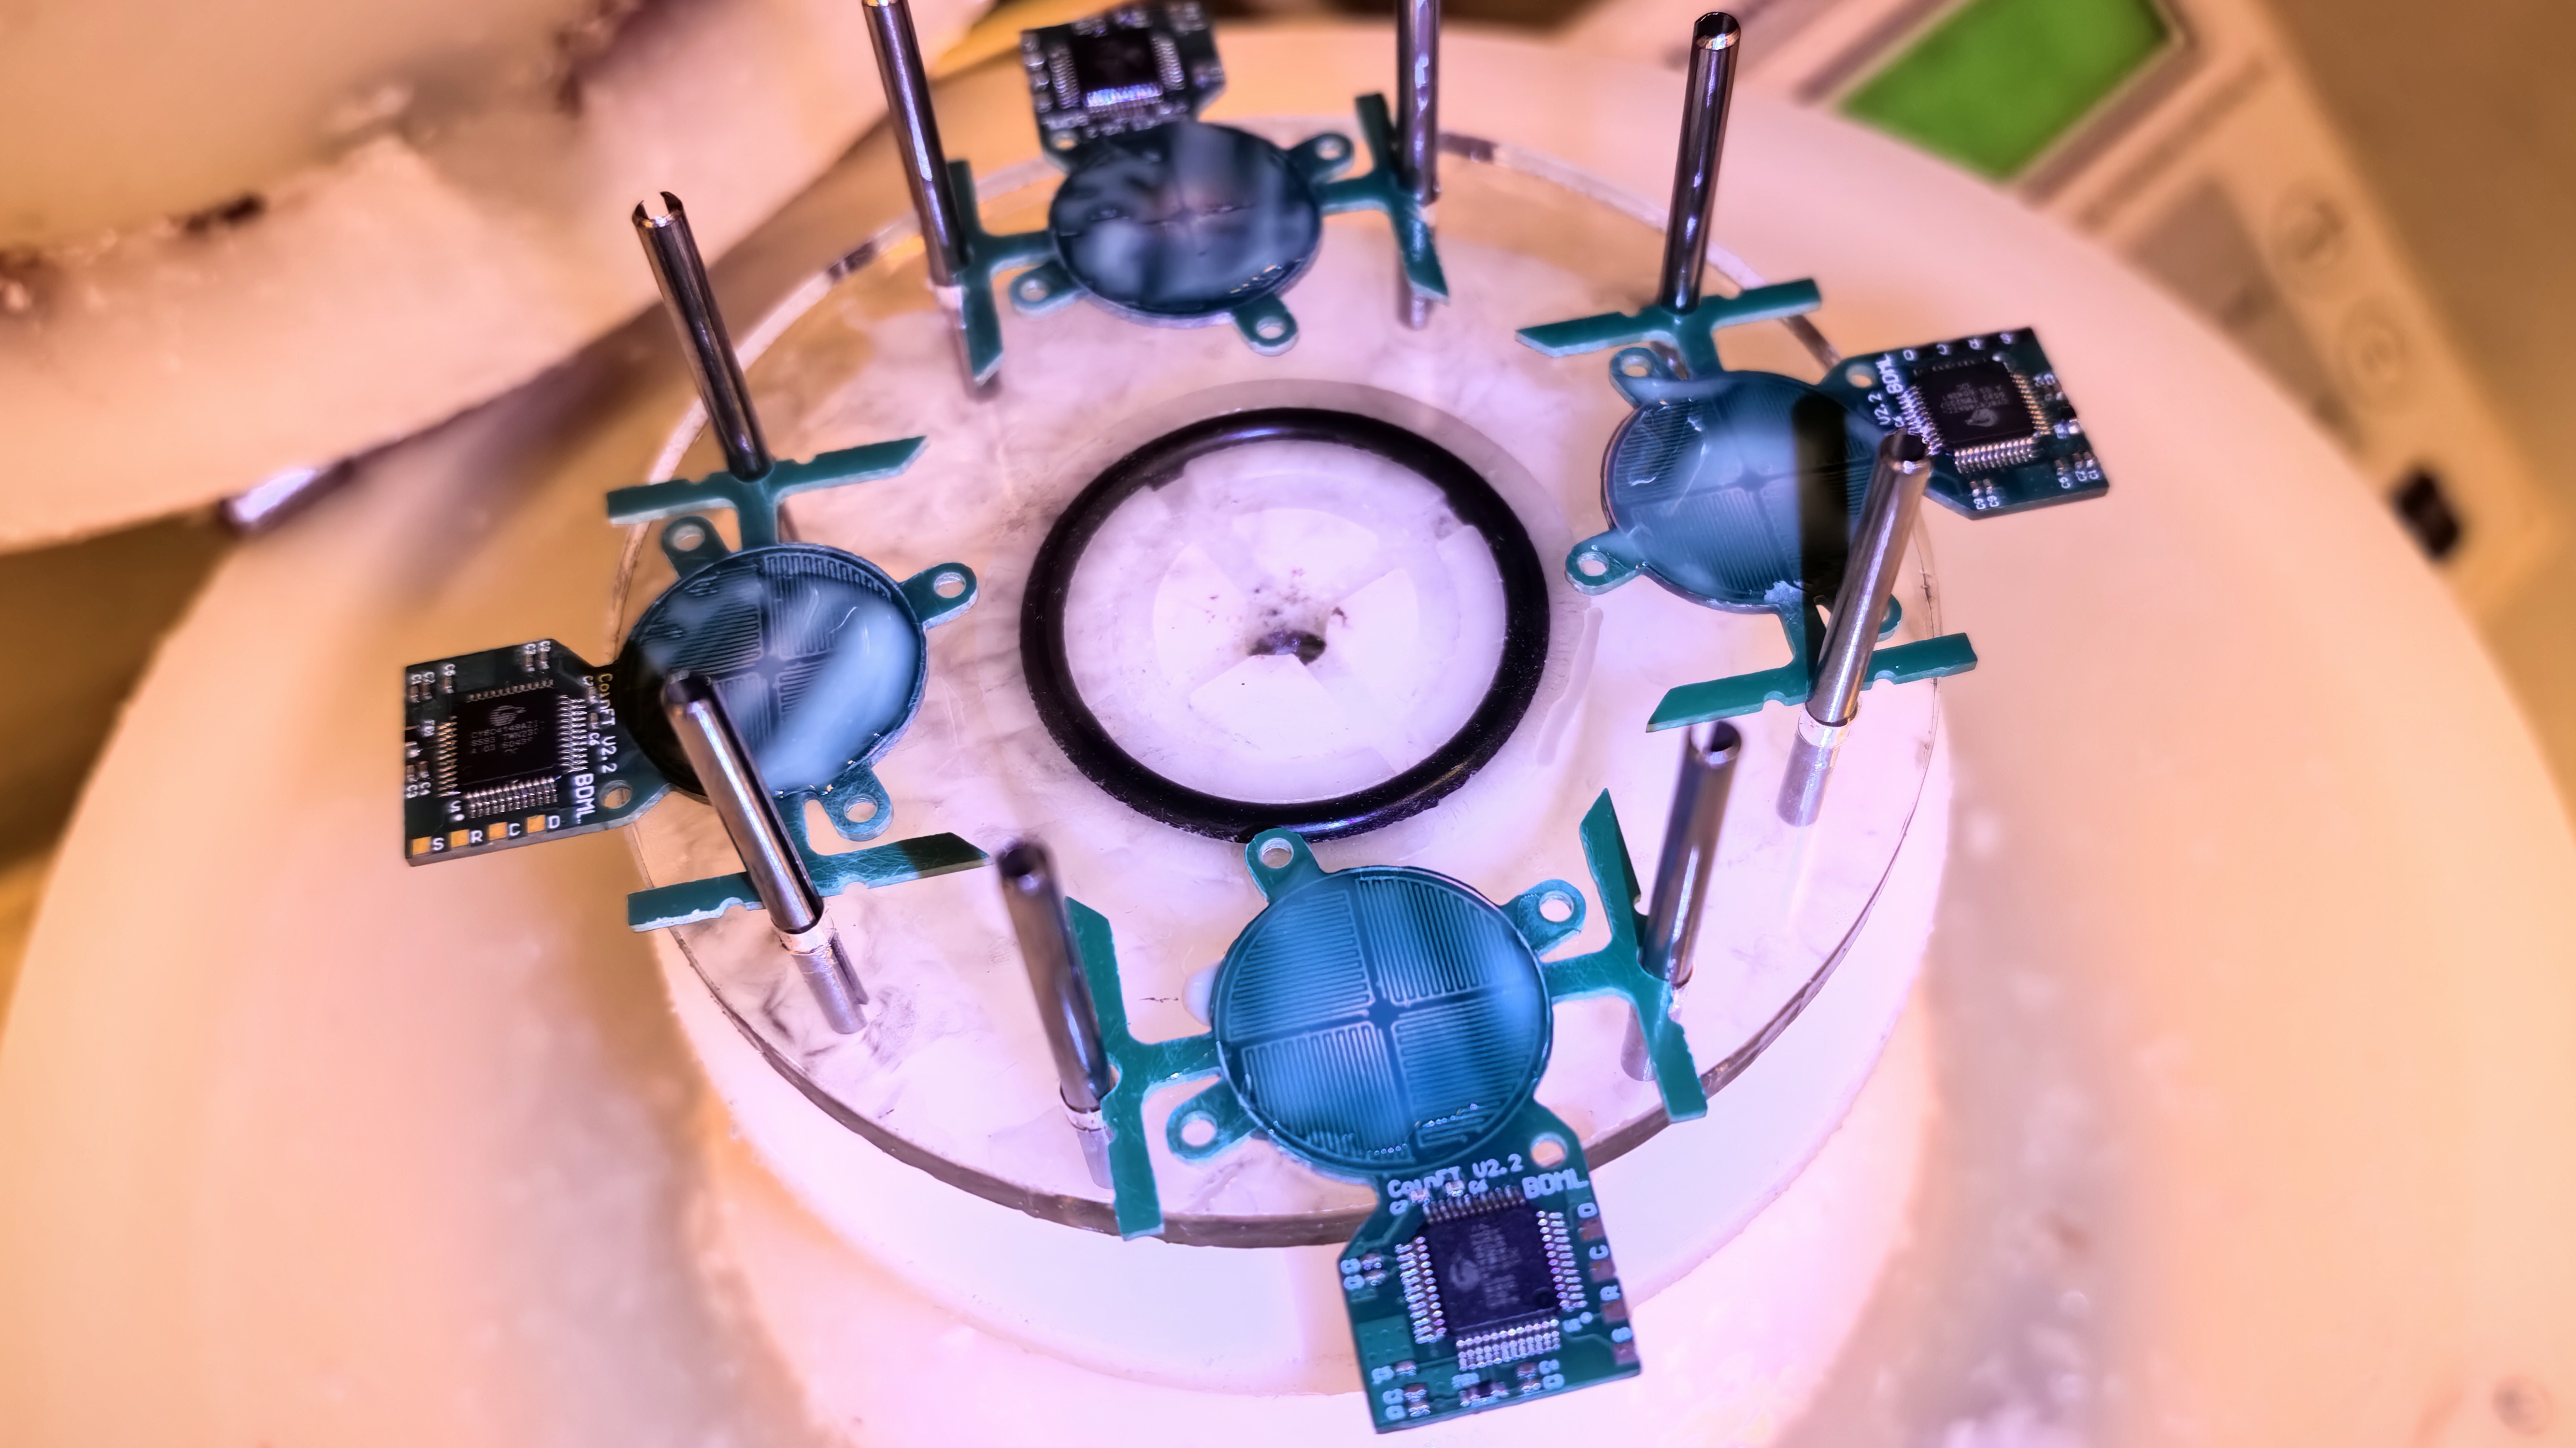
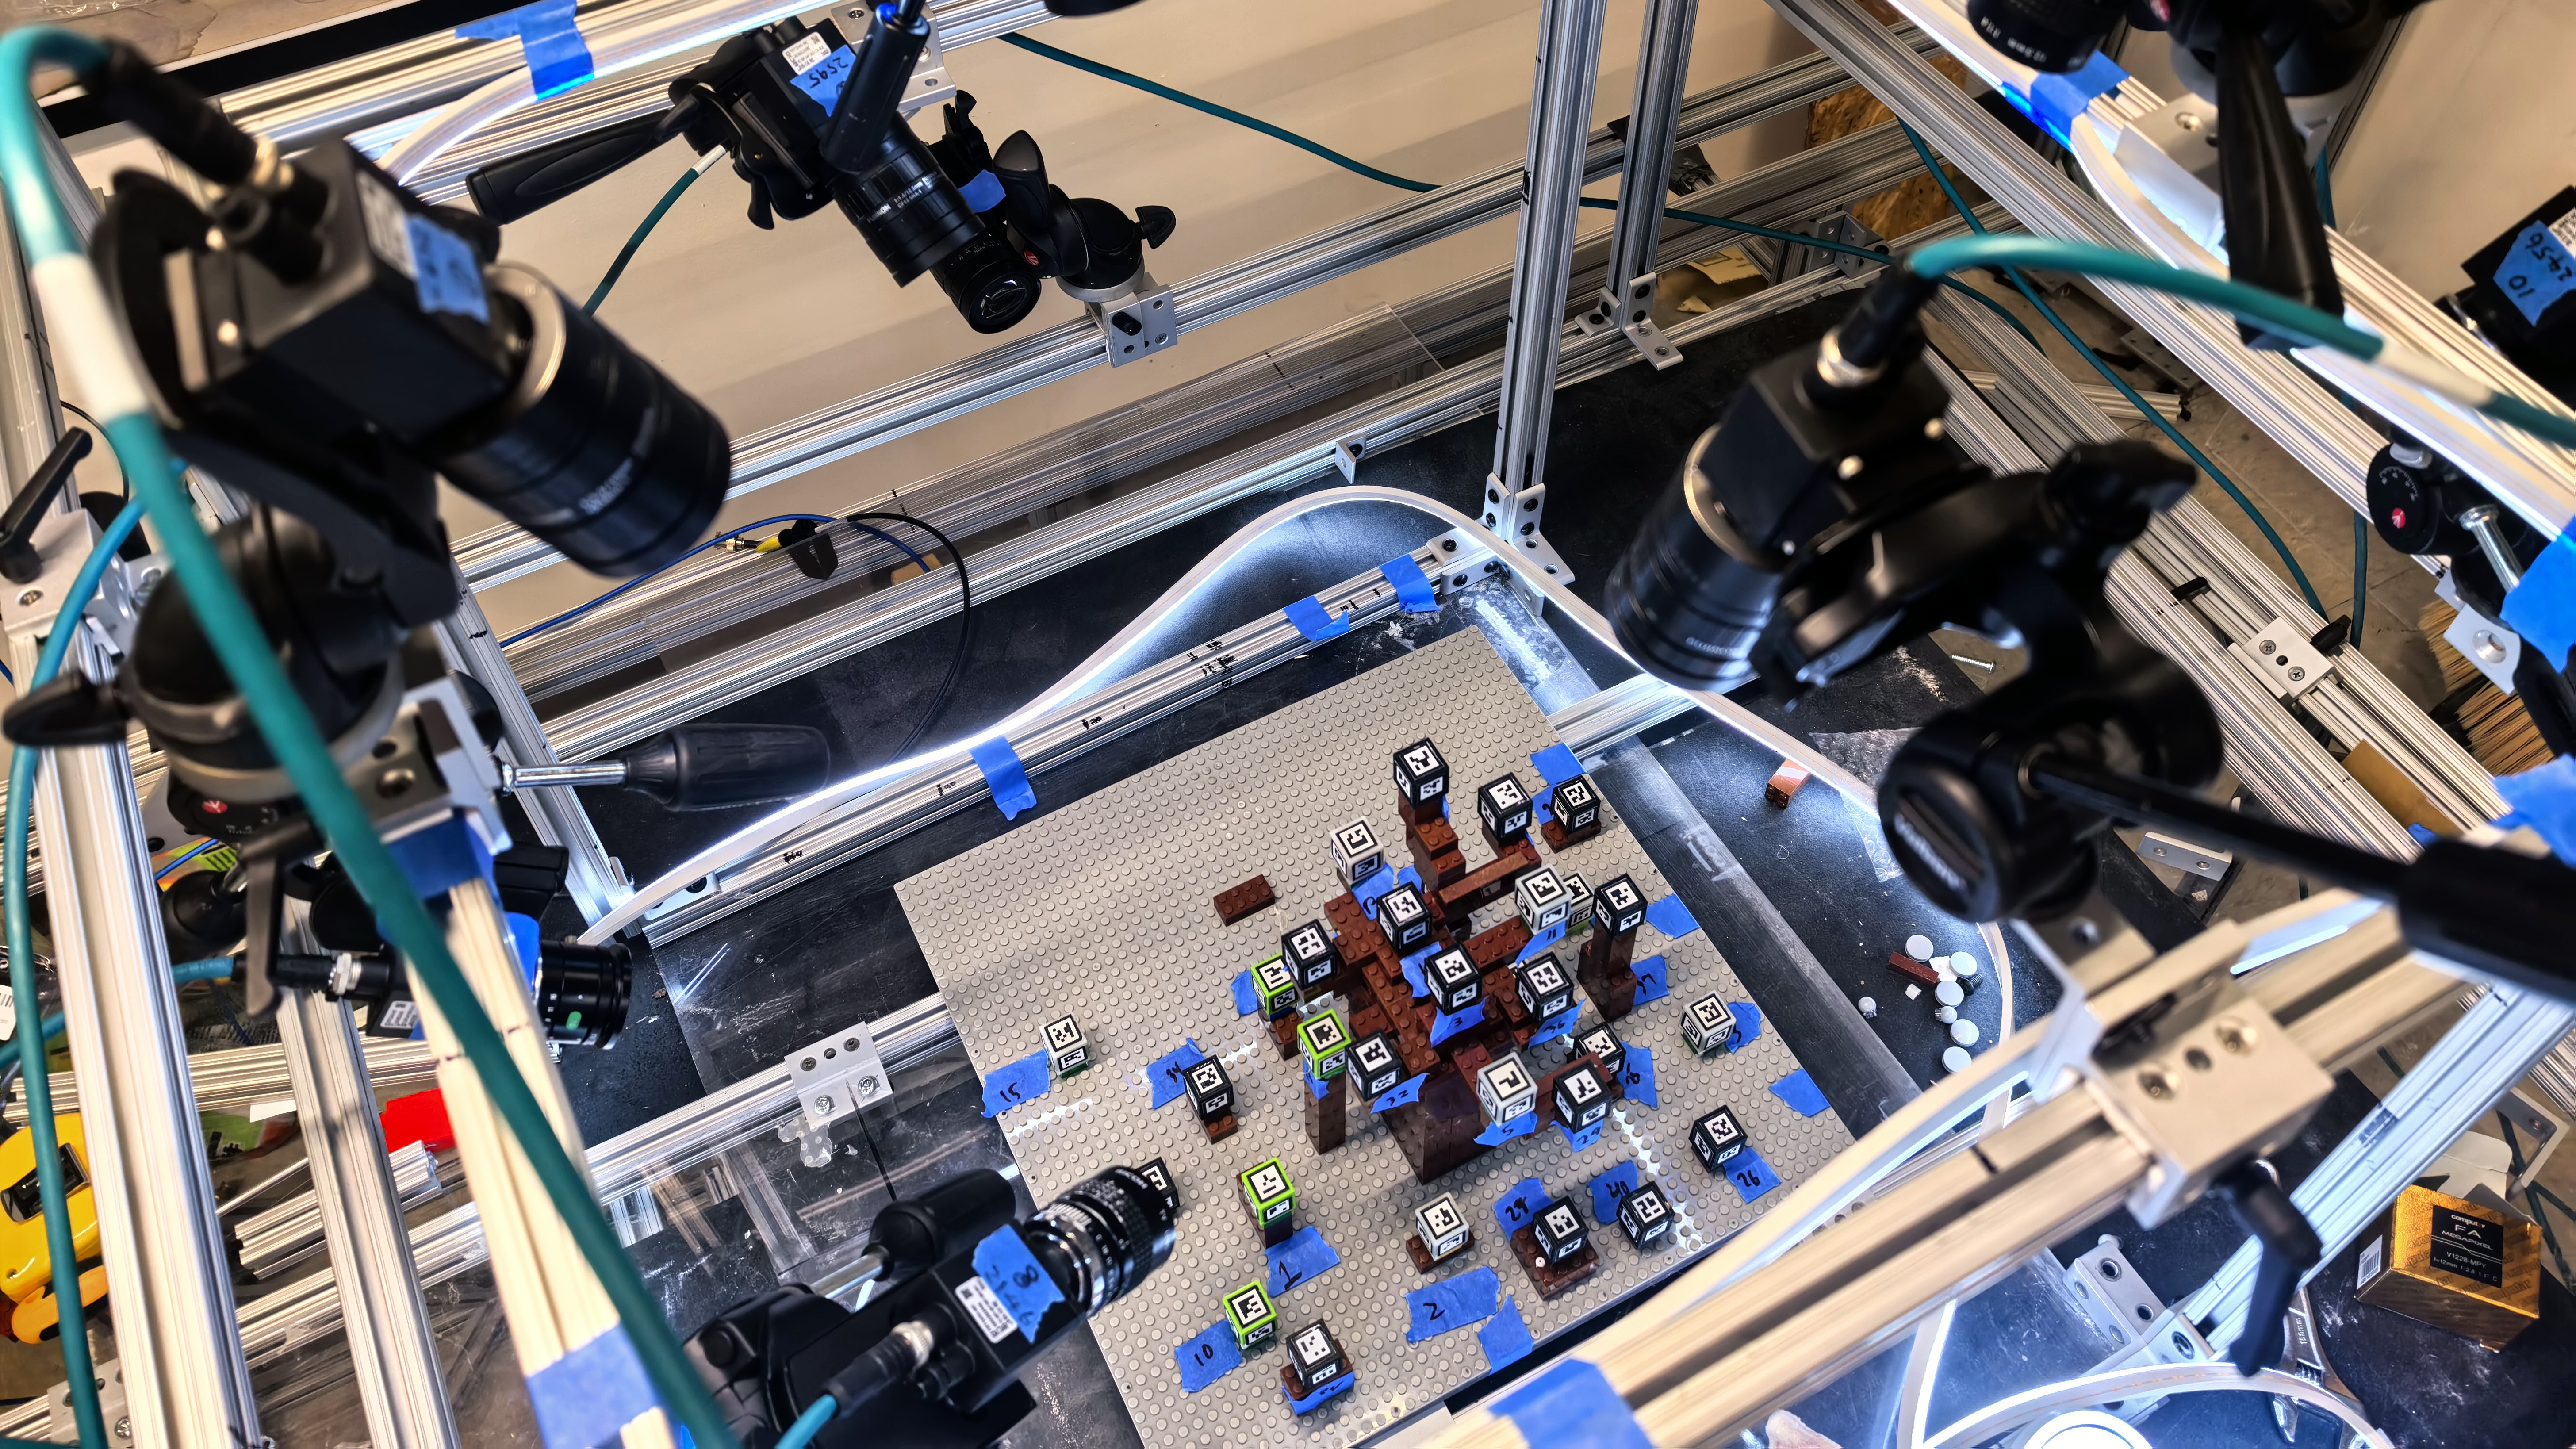
This work spans three related threads in Prof. Chen Li's Terradynamics Lab. The Cockroach Robot explores how body shape and compliance let a robot roll through cluttered obstacles rather than avoiding them, and is now being fitted with a real force/torque sensor to directly measure that interaction. CoinFT is that sensor, a coin-sized capacitive 6-axis force/torque sensor originally developed at Stanford's Biomimetics and Dexterous Manipulation Lab, fabricated, calibrated, and now deployed for the first time on the cockroach robot as a real robotic application. Jumping Spider Camera Systems covers two generations of multi-camera infrastructure built to support jumping spider locomotion research, from an early Raspberry Pi array to a current 28-camera machine vision system.